
MyTechDailyNews Software Breakdown: Siemens' Fuse EDA AI Agent Now Polices Itself Through Multi-Hour Runs
For anyone who spends the working day watching simulation queues, the interesting detail in the newest Fuse EDA AI Agent update is not the headline partnership — it is a change in execution lifetime. An agent no longer has to end its turn after the first tool call: it can stay attached to a job for hours, launch a run, read the returned logs, locate the failure, edit the configuration, submit again, and keep checking its own decisions against established engineering engines while it works. This MyTechDailyNews Software piece treats that behaviour as a software release rather than as news noise: what changed in the stack, which components are involved, what the runtime and access model implies for IT support and security owners, and how a design team should judge whether it is ready to pilot.
What changed, in software terms
- Session lifetime. The expansion released at DAC 2026 adds long-running agents that continue working after the first tool call instead of stopping there.
- A supervisory loop, not a chat assistant. The agent monitors a workflow, inspects results, alters its configuration and runs further operations, measuring progress against established EDA engines.
- Reasoning layer. Nvidia's Nemotron 3 Ultra provides reasoning for planning and multi-step execution, while the Nvidia NeMo Gym open library is used to evaluate agent behaviour so results improve and workflows are optimised.
- Runtime isolation. Agent execution is hosted in the Nvidia OpenShell secure runtime.
- Integration surface. EDA applications are reached through Model Context Protocol (MCP) interfaces.
- Enterprise home. The system is integrated into Intelligence Center X, Siemens' recently launched industrial AI environment, which supports agent creation and orchestration.
- Engines behind the decisions. Capability spans Catapult high-level synthesis, Solido custom IC design and verification, Aprisa physical implementation, Calibre signoff verification and Tessen design-for-test.
- Availability. The expanded capabilities arrive in upcoming releases of the AI-native EDA portfolio.
Three release stages of the same stack
| Stage | What the layer contributed | What a team could do with it |
|---|---|---|
| DAC 2025 — Fuse EDA AI System | Data and model infrastructure for applying generative AI to EDA data | Build on a foundation; humans still supervised every run |
| Nvidia GTC, March 2026 — Fuse EDA AI Agent | Execution layer: a supervisory agent that breaks an engineering objective into tasks, delegates to specialised agents and connects to EDA applications through Model Context Protocol (MCP) interfaces | Plan and dispatch work across tools |
| DAC 2026 — latest expansion | Long-running agents plus self-verifying workflows, orchestrated inside Intelligence Center X | Let an agent monitor, react and rerun across hours-long jobs |
| Fuse EDA AI platform roadmap | End-to-end orchestration and self-verifying, long-running agents | Move from the foundational AI architecture of 2025 to the 2026 target state |
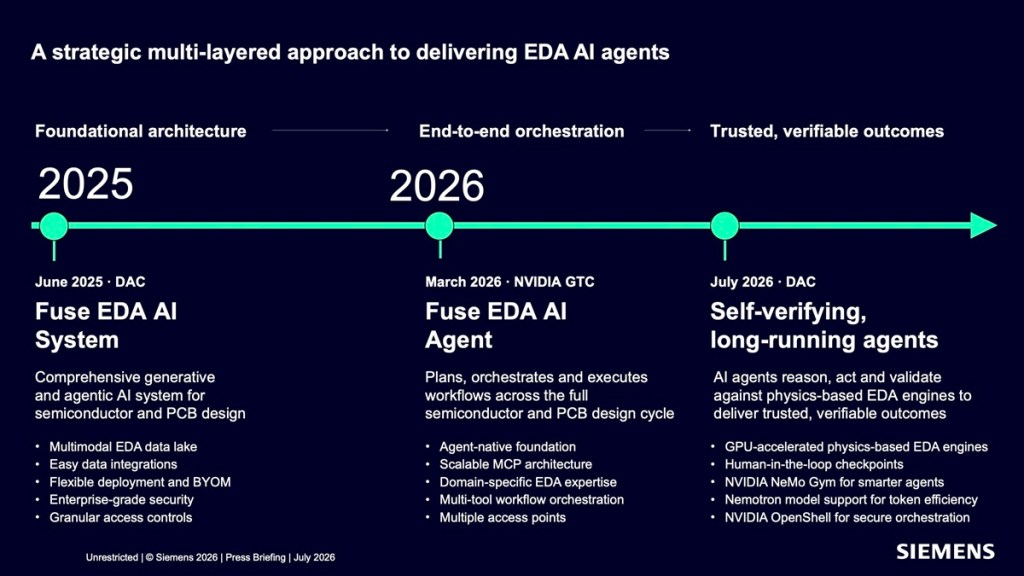 Figure 1 — Roadmap view: the Fuse EDA AI platform advances from a foundational AI architecture in 2025 to end-to-end orchestration and self-verifying, long-running agents in 2026. (Image: Siemens)
What "self-verifying" actually means here
Siemens uses the term self-verification for a specific division of labour. A language model alone does not decide whether a design is correct. Planning and interpretation may be model-driven, but the engineering evidence behind the next decision is produced by simulation, verification and physical design tools.
The practical consequence is that the agent's authority is bounded. It can watch a workflow, inspect results, change a configuration and trigger other operations, yet each step is checked against deterministic engines: across Siemens EDA that means Catapult, Solido, Aprisa, Calibre and Tessen, together with agentic workflows built on the Solido Characterization Suite.
Timothy Costa, general manager for industrial and computational engineering at Nvidia, stated the design principle plainly: "The goal is not to replace physics with AI". His description of the objective is to connect AI reasoning with accelerated simulation and physics-aware models while keeping trusted engineering tools as the source of validation.
Worked example: library characterization, step by step
A standard-cell, memory or custom-IP library must be characterized across its operating conditions before its timing and power models are usable. That is exactly the kind of task where supervision, not raw solve speed, dominates the calendar, and Siemens reports that library characterization using the Solido Characterization Suite with agentic AI reduces characterization turnaround by more than 10× and token cost by 5× to 10×.
- Environment bring-up. Configure the library and run preliminary simulations to confirm the environment behaves. Amit Gupta, senior vice president and general manager of Solido Custom IC and chief AI strategy officer at Siemens EDA, Siemens Digital Industries Software, calls this phase "pipe cleaning".
- Stabilise the setup. When a run fails because of an incorrect setup or a convergence issue, the result must be inspected, the configuration changed and the task rerun; only a stable setup earns the full characterization pass.
- Full run under supervision. Characterization proceeds across conditions while engineers keep tracking failures, reviewing outliers and deciding whether additional process, voltage and temperature (PVT) corners must be simulated before the Liberty models pass quality checks. "It comes out to about a four-to-six-week process for a library," Gupta said.
- The agent-led version of the same loop. An engineer initiates the process with a single prompt; the agent launches hours-long runs, monitors them, reacts to failures, changes configurations, reruns jobs and performs the final quality-assurance steps.
- Model output. Liberty files are generated and verified automatically by the workflow rather than assembled by hand.
Why this still matters even though the underlying simulations were already automated: most elapsed time in steps one to three sits between runs, in human attention. Siemens attributes the productivity gain to reducing that manual interlude, while Nvidia CUDA-X libraries accelerate numerical operations used by the simulation and physical verification tools, shortening the delay between an agent's action and the feedback it needs for the next decision.
Component roles at a glance
| Component | Role in the workflow |
|---|---|
| Solido Characterizer | Manages the characterization tasks |
| Solido LibSPICE | Runs the circuit simulations |
| Solido Generator | Produces the Liberty models |
| Solido Analytics | Examines the results and supports outlier analysis |
| Nvidia Nemotron 3 Ultra | Reasoning for planning and multi-step execution |
| Nvidia NeMo Gym | Open library used to evaluate agent behaviour, improve results and optimise workflows |
| Nvidia OpenShell | Secure runtime providing the environment in which the agents run |
| Nvidia CUDA-X | Accelerated numerical operations behind simulation and physical verification |
| Nvidia PhysicsNeMo | Open-source PyTorch framework for physics AI models that give the agent fast estimates to explore a design and decide where a higher-fidelity simulation is required |
| Model Context Protocol (MCP) | Interface through which the agents connect to EDA applications |
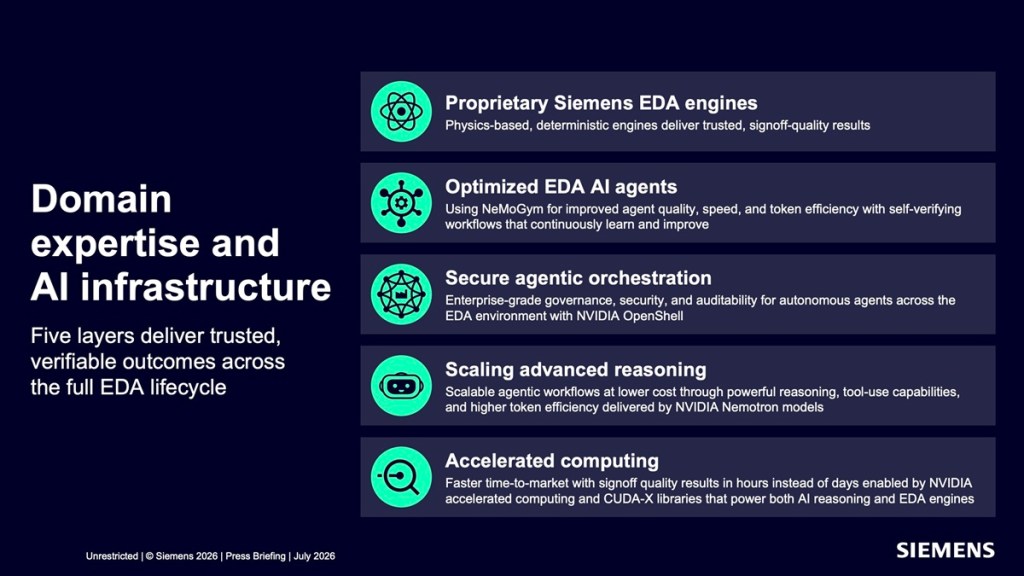 Figure 2 — Architecture view: deterministic EDA engines, optimised AI agents, secure orchestration, Nemotron reasoning models and CUDA-X accelerated computing combined in Siemens' self-verifying EDA architecture. (Image: Siemens)
Costa's caution applies directly to the PhysicsNeMo row: those models are not a substitute for engineering validation. Trusted solvers, test data and domain-specific criteria remain the final references.
Runtime, access and oversight: notes for IT and security owners
- Where it executes. Agent creation and orchestration happen inside an enterprise industrial AI environment, Intelligence Center X, and the agents themselves run in the Nvidia OpenShell secure runtime — treat both as in-scope for platform review, not as a desktop plug-in.
- What it touches. Agents reach applications through MCP interfaces, and their demonstrated behaviour includes launching runs, editing configurations and rerunning jobs. Access review should therefore cover which engines an agent may invoke and which design data is exposed to it.
- Human control points. Engineers must be able to observe the agent's actions, pause or stop execution and redirect the workflow; Gupta's reasoning is that an agent repairing one issue can create another physical problem.
- Rollout shape. Near-term deployment of this capability stays domain-scoped and supervised.
- Where to get it. The expanded EDA AI capabilities will be available in upcoming releases of the AI-native EDA portfolio.
Where the autonomy stops for now
The library characterization example has well-defined inputs, tools and acceptance checks. Stretching the same autonomy over several EDA domains is harder, so Siemens is currently focused on long-running agents inside individual areas such as custom IC design, digital verification, design-for-test and Calibre physical verification. "What we see as the next step is being able to stitch those product families together," Gupta said.
An early demonstration exists: Calibre detects a design rule violation and the agent invokes Aprisa semiconductor software for a digital physical design repair, or Solido for an analog repair. That step from identifying a problem to changing the design also multiplies verification obligations, because fixing a local design rule check violation can create a timing, congestion or signal-integrity problem elsewhere in the design.
Exposing additional applications through MCP is, in Gupta's explanation, the smaller part of the challenge. A cross-domain agent also has to understand how different representations of the same design correlate with one another, which is why Siemens is developing EDA ontologies that map relationships between domains and improve the models' ability to handle different data types. The context is necessary because a change at one stage may invalidate results elsewhere.
Common misconceptions
- "The model signs off the design." No. A model may decide which SPICE analysis to run or whether another PVT corner is needed, but the simulator produces the electrical result.
- "This is a faster solver." The gain is in the supervisory loop between runs; speed comes from removing manual waiting, plus CUDA-X acceleration of numerical operations.
- "Agentic EDA retires the physics tools." The agent keeps the workflow moving and decides what should happen next, while the deterministic EDA engines and human engineers determine whether the results can be trusted.
- "Any workflow can be delegated today." Demonstrated scope is domain-scoped and supervised, with cross-domain stitching described as the next step.
FAQ
Is this a new product or an update to an existing one?
An extension of an existing line. The Fuse EDA AI System shown at DAC 2025 supplied the data and model infrastructure; the Fuse EDA AI Agent announced at GTC in March 2026 added the execution layer; the DAC 2026 expansion adds the long-running, self-verifying agents.
Which parts are AI and which are traditional EDA?
Planning, delegation and interpretation are agentic and model-driven — Nemotron 3 Ultra for reasoning, NeMo Gym for evaluating agent behaviour. The acceptance evidence still comes from deterministic tools: Catapult, Solido, Aprisa, Calibre and Tessen, along with the Solido Characterization Suite components.
How much of a manual characterization cycle is waiting and supervising?
Siemens describes the human share as bring-up, failure handling, outlier review and corner decisions inside a window Gupta sizes as "a four-to-six-week process for a library". Automating that loop with the Solido Characterization agent is what the company credits for more than 10× faster turnaround and 5× to 10× lower token cost.
Can the agent change my design without me?
In its current, near-term posture it is domain-scoped and supervised, and the workflow keeps explicit control points for observation, pause, stop and redirect. The repair flow linking Calibre to Aprisa or Solido is an early example, not an unattended default.
Do I need new hardware to run this?
The software stack links Siemens EDA with Nvidia open models, agent software, secure runtime and accelerated computing; Nvidia CUDA-X is used for numerical operations behind simulation and physical verification, and PhysicsNeMo-based physics models supply fast estimates for exploration. Engineering validation still rests on the existing EDA engines.
Action checklist for evaluation
- Pick one workflow with fixed inputs, fixed tools and written acceptance checks — library characterization is the reference case in this release.
- Map which deterministic engines hold signoff authority for that workflow (Catapult, Solido, Aprisa, Calibre, Tessen) and treat their outputs as the verification record.
- Inventory the MCP-connected applications and decide, per agent, what it may launch, edit or rerun.
- Define the human intervention points: who monitors, what triggers a pause, and how a redirected run is handled.
- Use physics-aware estimates only for triage and exploration, never as signoff.
- Track the Fuse EDA AI platform stages from 2025 to 2026 when scoping adoption; cross-domain stitching arrives after the domain-scoped agents.
Read as a release note rather than as a partnership story, this update carries a narrow and testable promise: software agents that survive multi-hour jobs and police themselves against the engines your team already trusts. If your bottleneck is human attention between runs, that promise is measurable on the next project; if your bottleneck is raw solver throughput, this changes the wrapper around the physics, not the physics itself.
Written by Sarah Chen, Tech Daily — Software desk. Contact: hello@techdaily.com